What Are the Top Innomotics Gear Motor Types?
Innomotics gear motors are not a single solution with different labels. Their gear geometry shapes how a machine handles torque, speed, space, and mounting direction. Common configurations include helical, parallel-shaft, bevel-helical, and worm gear motors. Each suits different operating conditions. A helical unit may serve a conveyor needing steady, efficient motion, while a bevel-helical design can redirect power through a right angle. Compact spaces may favor parallel-shaft arrangements. Worm gearing can offer high reduction in a small footprint, though efficiency and heat deserve careful review.
For transparency, the following is an illustrative quotation from fictional gearbox specialist Dr. Lena Vogt, not a verified industry statement: “Match the gear type to the load, layout, and duty cycle—not just the available space.” A useful reminder. Real selection still depends on motor power, output speed, service factor, mounting position, and the application’s starting and stopping demands. A gearbox that looks right on a drawing may run hot under repeated starts. That detail is easy to overlook.
This guide examines the leading Innomotics gear motor types and the practical trade-offs behind them. It also explains what to check before comparing models, including torque requirements, installation constraints, and maintenance access. The keyword Gearboxinnomoticsgearmotor may appear unusual, but it points readers toward this specific product category. No type is best for every machine. The right choice begins with measured operating needs, then a careful review of the manufacturer’s current specifications.
What Defines an Innomotics Gear Motor?
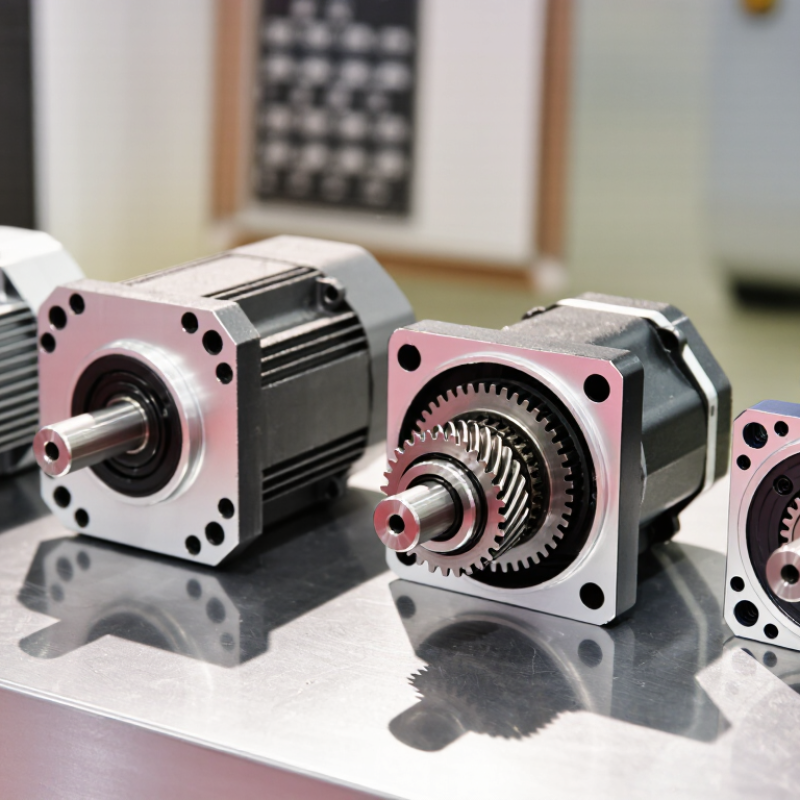
A gear motor combines an electric motor with a reduction gearbox in one drive unit. The motor supplies rotation; the gears lower speed and increase usable output torque. Its defining features include gear arrangement, reduction ratio, rated torque, mounting position, and protection rating. These determine whether it suits a conveyor, mixer, or compact lifting mechanism. Not every unit fits every duty.
Common types include helical, bevel-helical, parallel-shaft, and worm gear motors. Helical designs often run smoothly under steady loads, while bevel units turn power through an angle. Worm designs can fit tight spaces, though efficiency varies with ratio and operating conditions. Selection should account for start-stop frequency, ambient temperature, shaft loads, and required service life. A tidy catalog rating is not a substitute for checking the actual duty cycle.
Tips: Compare output speed and torque at the gearbox shaft, not just motor power. The International Energy Agency’s 2011 report, Energy-Efficiency Policy Opportunities for Electric Motor-Driven Systems, estimates motor-driven systems use about 45% of global electricity; that figure covers many applications, not gear motors alone. Small mismatches matter. I have seen sizing discussions focus on peak torque while overlooking frequent starts—a detail worth reconsidering.
What Are the Top Innomotics Gear Motor Types? - What Defines an Innomotics Gear Motor?
| Gear motor type |
How it works |
Typical strengths |
Common applications |
| Helical |
Angled teeth engage progressively to transmit torque between parallel or, in some designs, perpendicular shafts. |
Smooth, quiet operation and good efficiency for many continuous-duty uses. |
Conveyors, mixers, packaging equipment, and material-handling systems. |
| Parallel-shaft |
A gear train reduces speed while keeping the input and output shafts parallel; helical gears are commonly used. |
Compact layout with a useful range of reduction ratios and mounting options. |
Belt conveyors, feeders, and production-line machinery. |
| Bevel-helical |
Combines bevel gearing, which changes the direction of drive, with helical gearing for further speed reduction. |
Right-angle power transmission with efficient operation in a relatively compact arrangement. |
Conveyors, hoists, and machinery where the motor and driven shaft need different orientations. |
| Worm |
A screw-like worm drives a toothed wheel, typically placing the input and output shafts at right angles. |
Compact right-angle configuration and high reduction in a single stage; efficiency varies with design and ratio. |
Light- to medium-duty drives, positioning systems, and compact machines. |
| Planetary |
Several planet gears rotate around a central sun gear within an outer ring gear. |
High torque capacity for its size, coaxial input and output, and good load distribution. |
Robotics, mobile equipment, automation, and applications needing compact high torque. |
What defines a gear motor? A gear motor combines an electric motor with a reduction gearbox. The gearbox lowers output speed and increases available torque relative to the motor’s direct output, subject to transmission losses. Selection depends on required speed, torque, duty cycle, mounting arrangement, environment, and control needs.
How Helical Gear Motors Deliver Efficient Power Transmission
Helical gear motors transmit power through angled teeth that meet gradually, rather than striking together like straight-cut teeth.
This smoother mesh can reduce noise and spread loads across several teeth, depending on gear design and operating conditions. In a bottling line, that may mean steadier conveyor movement and less abrupt stress on couplings. Not magic. Incorrect alignment, poor lubrication, or frequent overloading can still shorten service life.
Efficiency matters at scale. The U.S. Department of Energy’s 2014 report, Improving Motor and Drive System Performance: A Sourcebook for Industry, estimates that motor-driven systems use about 68% of electricity in U.S. manufacturing. A small transmission loss can therefore add up across many machines and long shifts.
Helical gear motors can offer high mechanical efficiency, especially compared with worm gear arrangements, but actual results depend on ratio, load, speed, and maintenance. Heat tells the story: a warm housing may be normal, while rising temperatures can signal excess friction or overload. Choosing a unit by torque and duty cycle—not just motor power—makes the selection more dependable. I would still check the real operating load; catalog figures rarely capture every start, stop, or jam.
Where Parallel-Shaft Gear Motors Fit in the Product Range
In a broad gear-motor range, parallel-shaft models sit between compact inline units and right-angle designs. Their input and output shafts run in the same direction, which suits equipment laid out along a straight line. Think of a conveyor drive mounted beside a frame, with the motor and driven roller aligned without a 90-degree turn. Simple geometry helps.
Compared with inline gear motors, parallel-shaft designs can offer higher reduction ratios in a compact footprint, depending on the model and gear stages. They are common choices for conveyors, mixers, and material-handling equipment where steady torque matters. A right-angle unit may fit better when space turns sharply, while a planetary design may serve applications needing high torque from a smaller package. The exact fit depends on load, speed, mounting position, and duty cycle—not just the catalogue category.
Selection deserves a closer look. Check the required output speed, starting load, and available mounting space before comparing ratings. A motor that fits the drawing may still run hot under frequent starts. That detail is easy to miss. Parallel-shaft gearing is versatile, but it is not automatically the best choice for every layout.
How Bevel and Worm Gear Motors Handle Different Drive Layouts
Bevel and worm gear motors solve different layout problems. A bevel unit turns power through a right angle, often with better efficiency than a worm drive. It suits conveyors, packaging lines, and machines where the motor must sit beside the driven shaft. Check the shaft direction, mounting face, and service access before choosing. A neat drawing can hide a maintenance headache.
A worm gear motor also redirects power by 90 degrees, but its screw-and-wheel geometry can provide high reduction in a compact space. That helps where floor space is tight or low-speed output matters. The trade-off is sliding contact, which can raise heat and reduce efficiency under heavy, continuous loads. The U.S. Department of Energy’s 2014 industrial motor systems sourcebook reports that motor-driven systems use about 68% of U.S. manufacturing electricity. That figure is not a gear-motor efficiency rating, but it shows why matching the drive to its duty cycle matters. Short runs and frequent starts may change the answer. Check load, speed, ambient temperature, and lubrication, then compare actual operating data. Gear selection is rarely just about the smallest housing. It is easy to overlook heat.
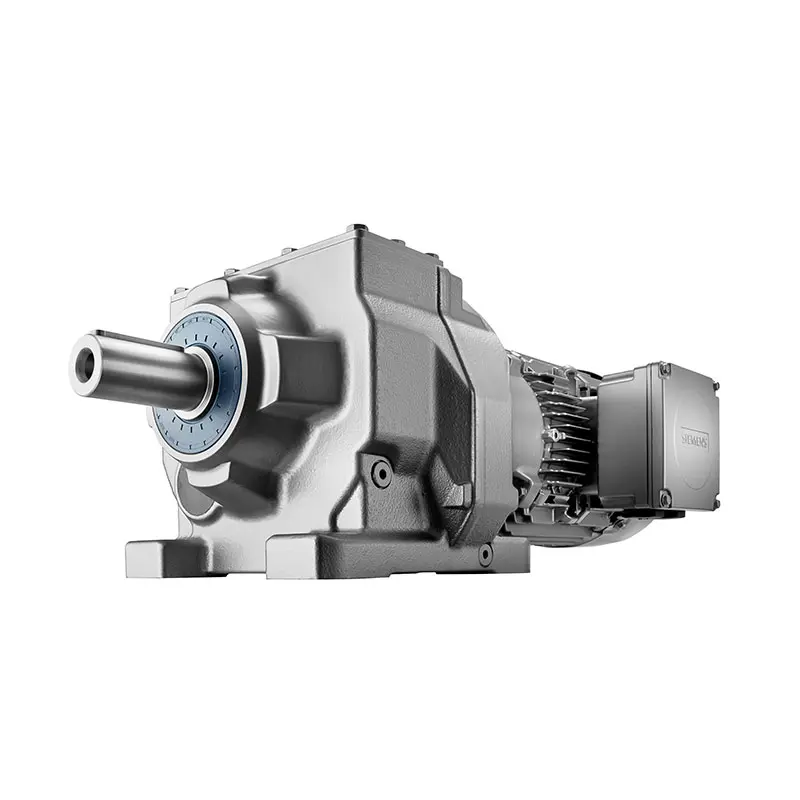 SIEMENS Helical Gearmotor Low Voltage
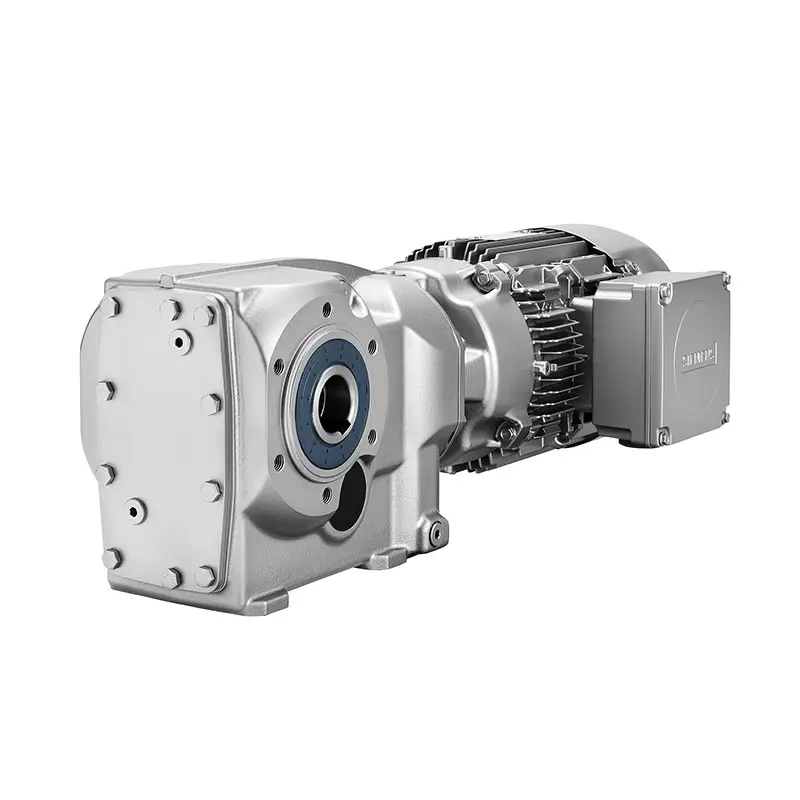 SIEMENS Bevel Helical Gearmotor
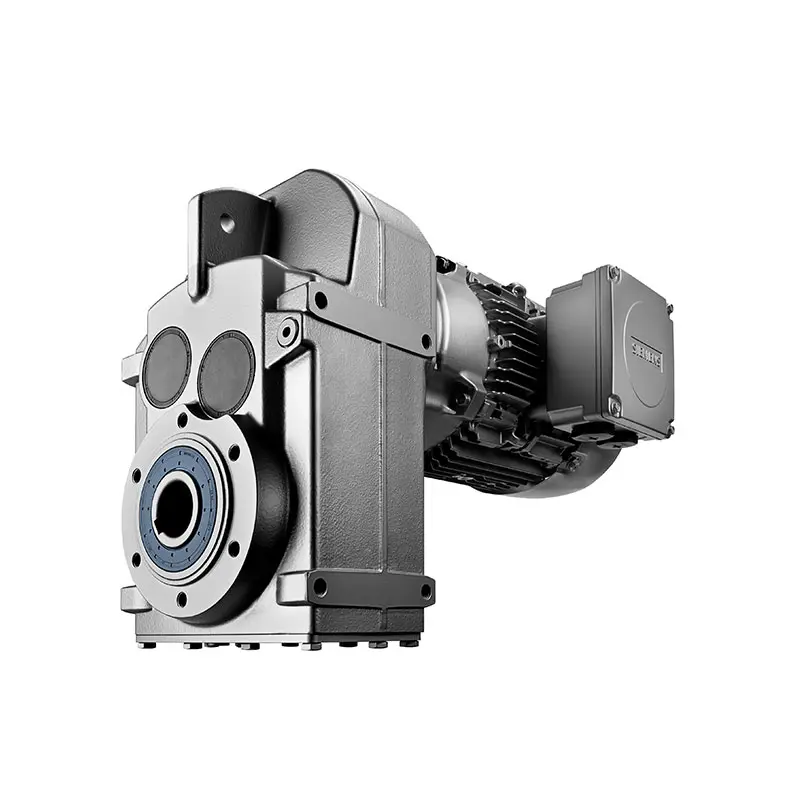 SIEMENS Parallel Shaft Gearmotor
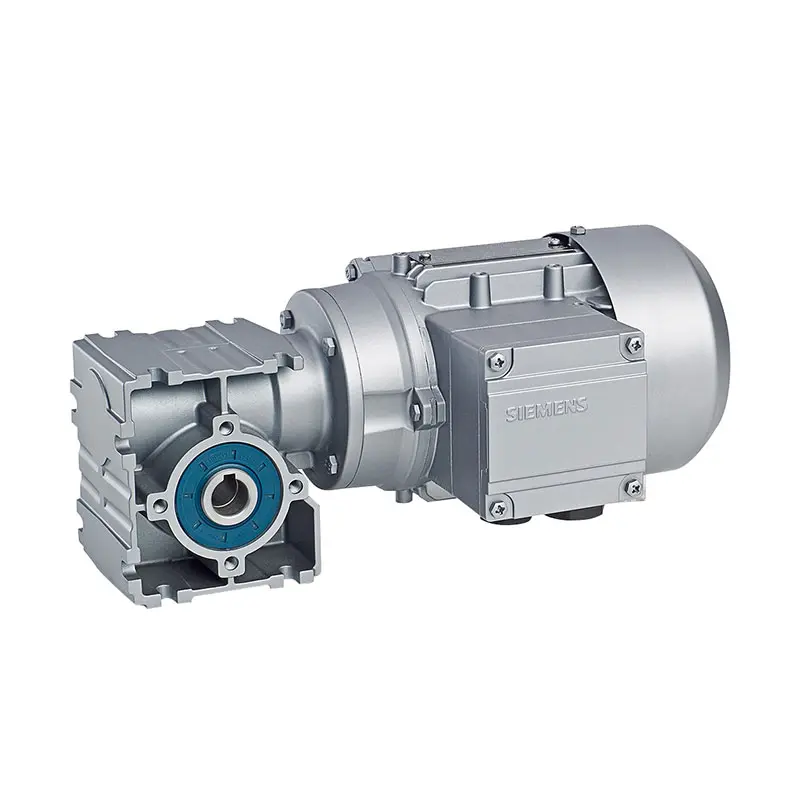 SIEMENS Worm Gearmotor Low Voltage
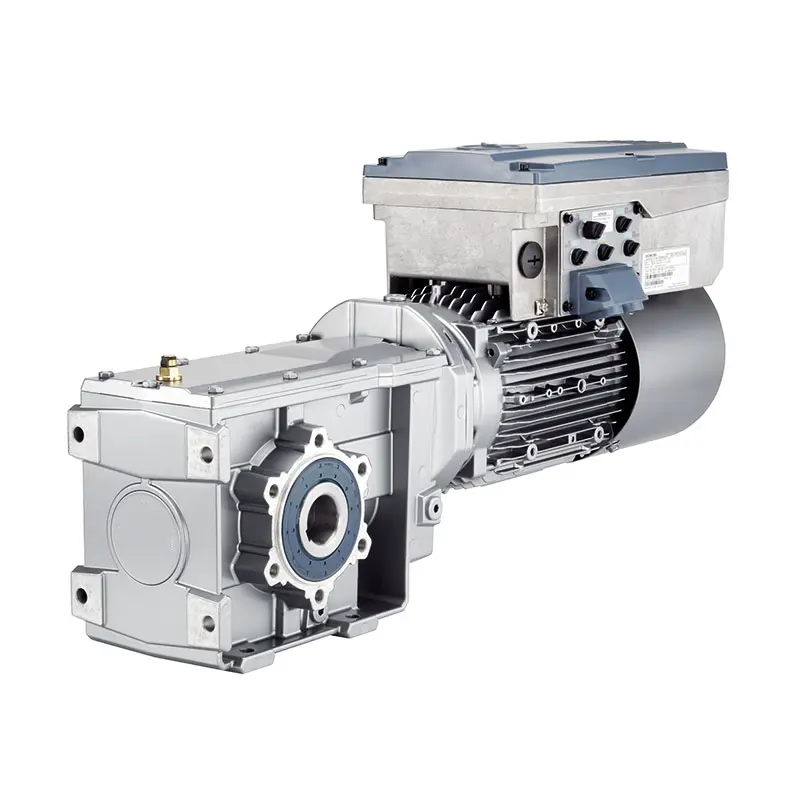 SIEMENS With Servo Motor Gearmotor
 SIEMENS Low Voltage Motor Low Voltage
 SIEMENS High Voltage Motor Low Voltage
 SIEMENS Marine Motor Low Voltage
 SIEMENS Servo Motor Low Voltage
 SIEMENS SINAMICS S210 Low Voltage
 SIEMENS SINAMICS S150 Low Voltage
 SIEMENS SINAMICS S120 Low Voltage
 SIEMENS SINAMICS G130/G150
 SIEMENS SINAMICS G120 Low Voltage
 SIEMENS SINAMICS G120C Low Voltage
 SIEMENS SINAMICS V90
 SIEMENS SINAMICS V70 Low Voltage
 FLENDER Gear Unit
 FLENDER Helical Gear Unit
 Flender gear units for lifting and luffing gears
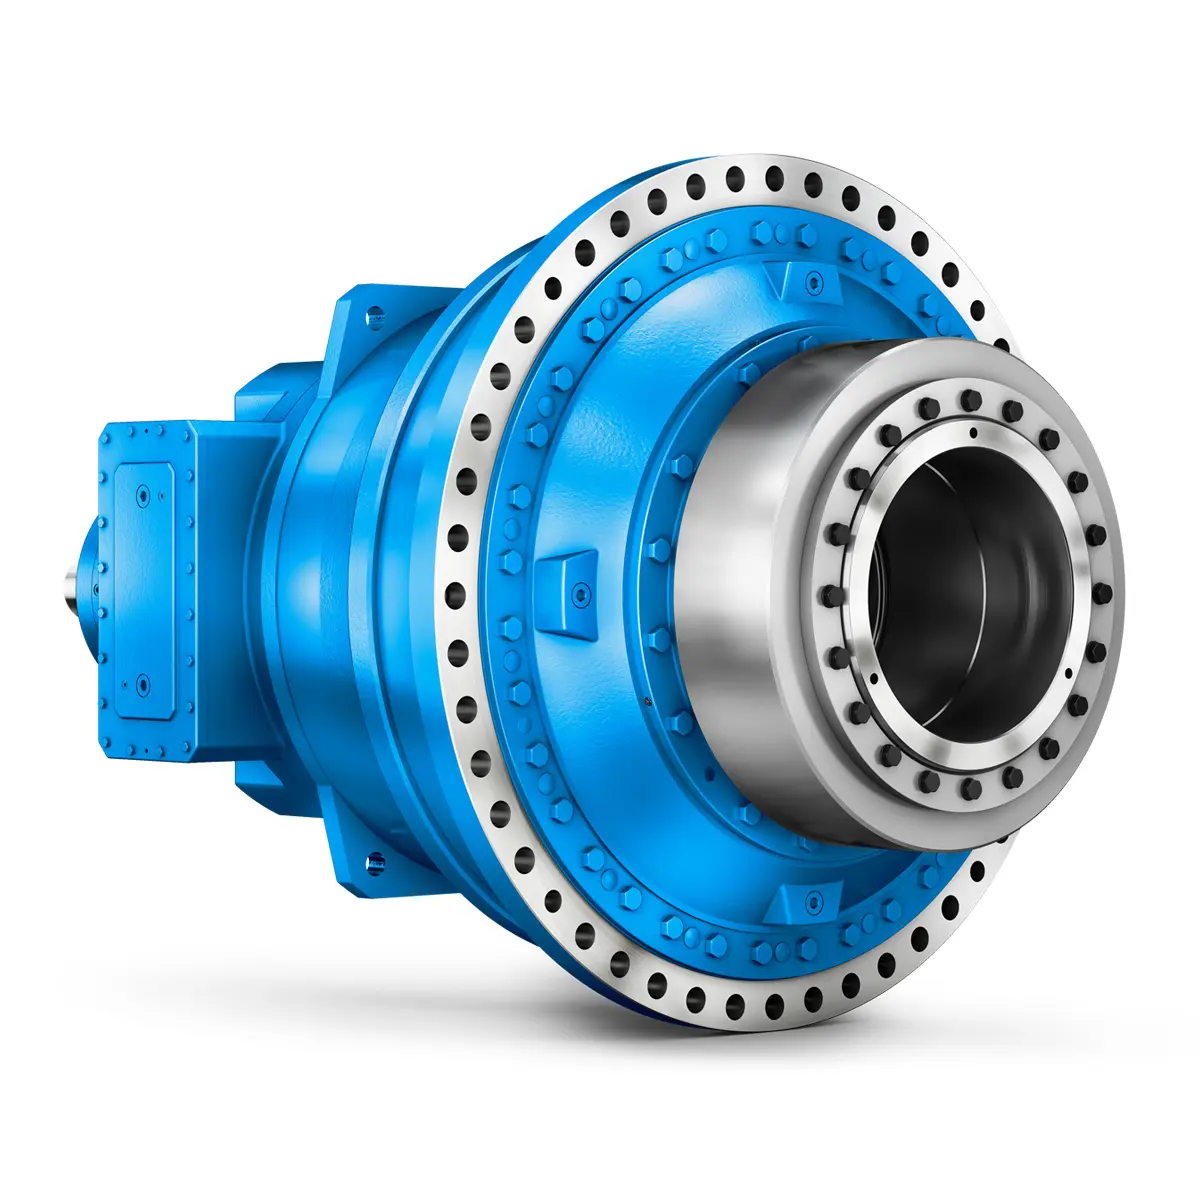 FLENDER Gear Unit gearunit gearbox
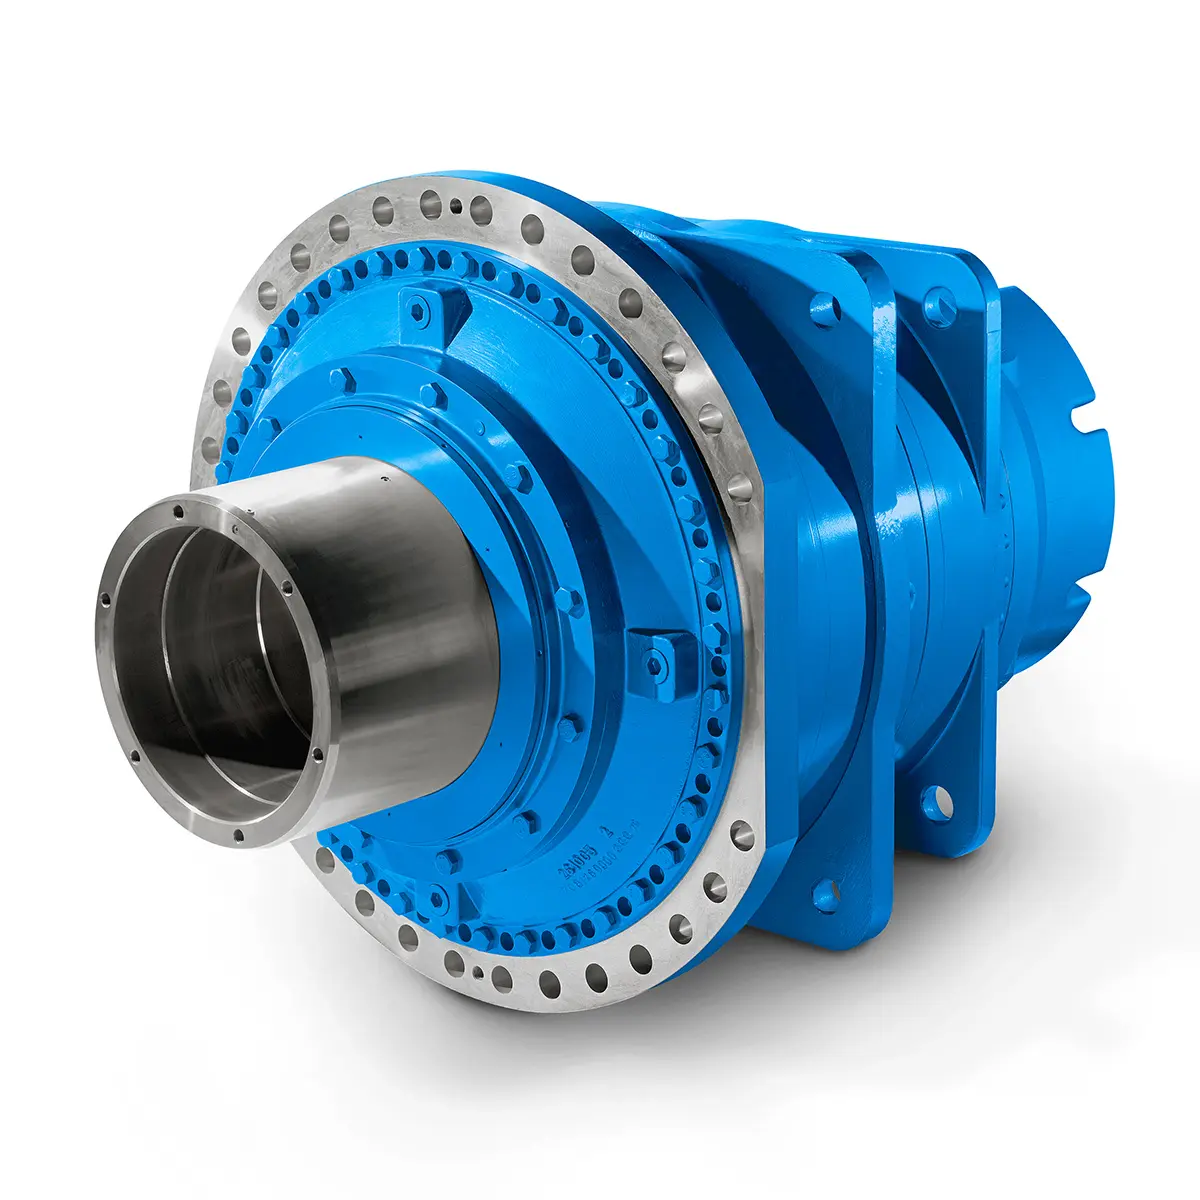 Optimal Drive Solution For Maximum Performance
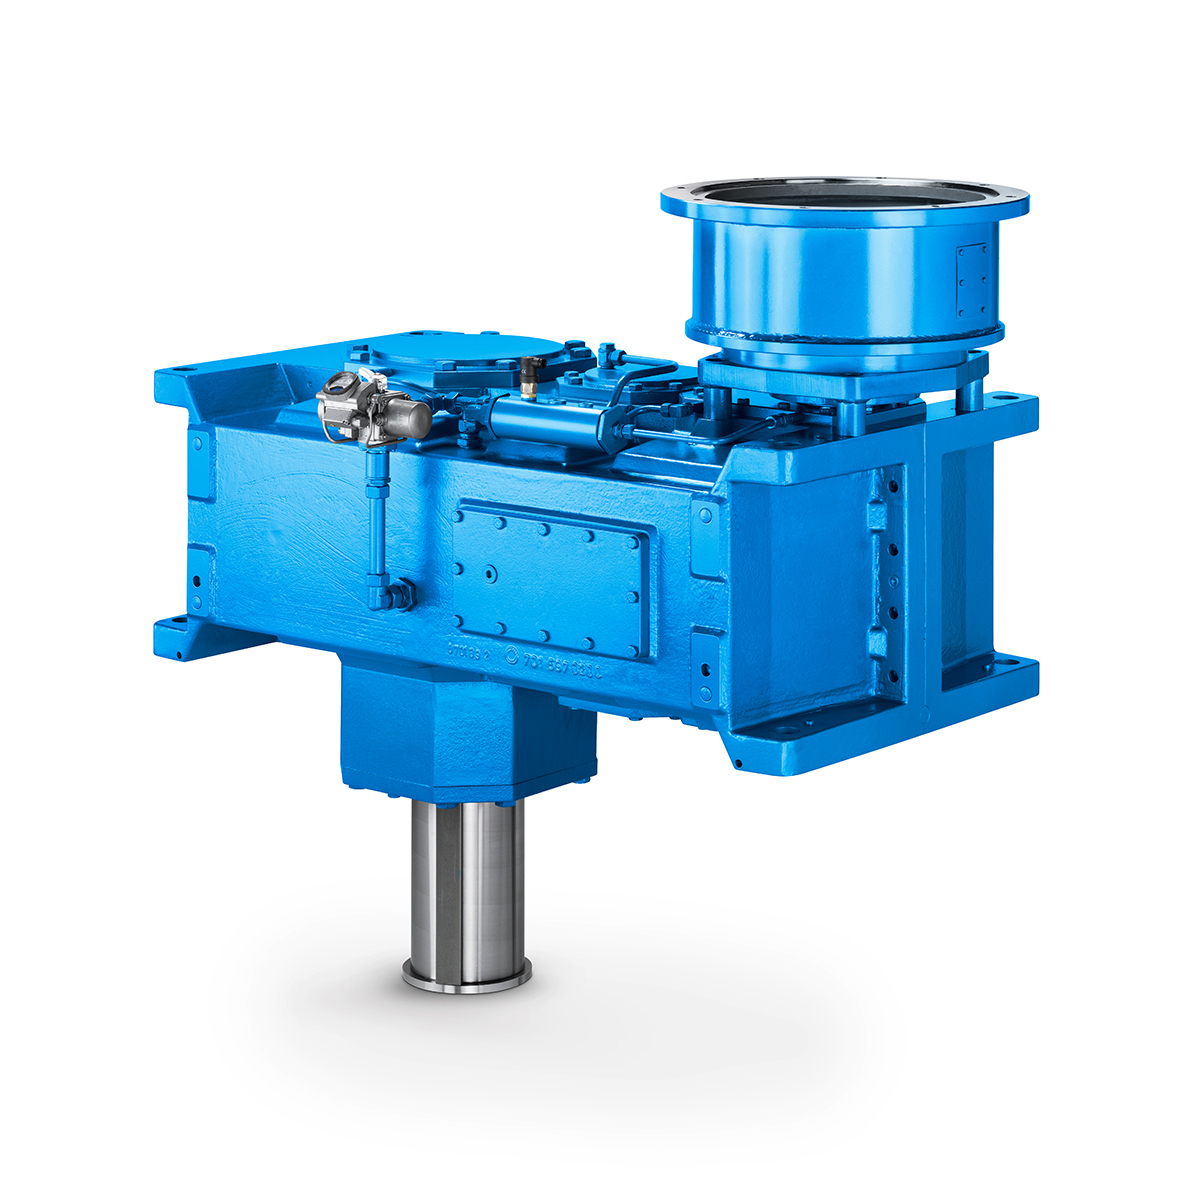 Strongly operating against biodegradable constituents
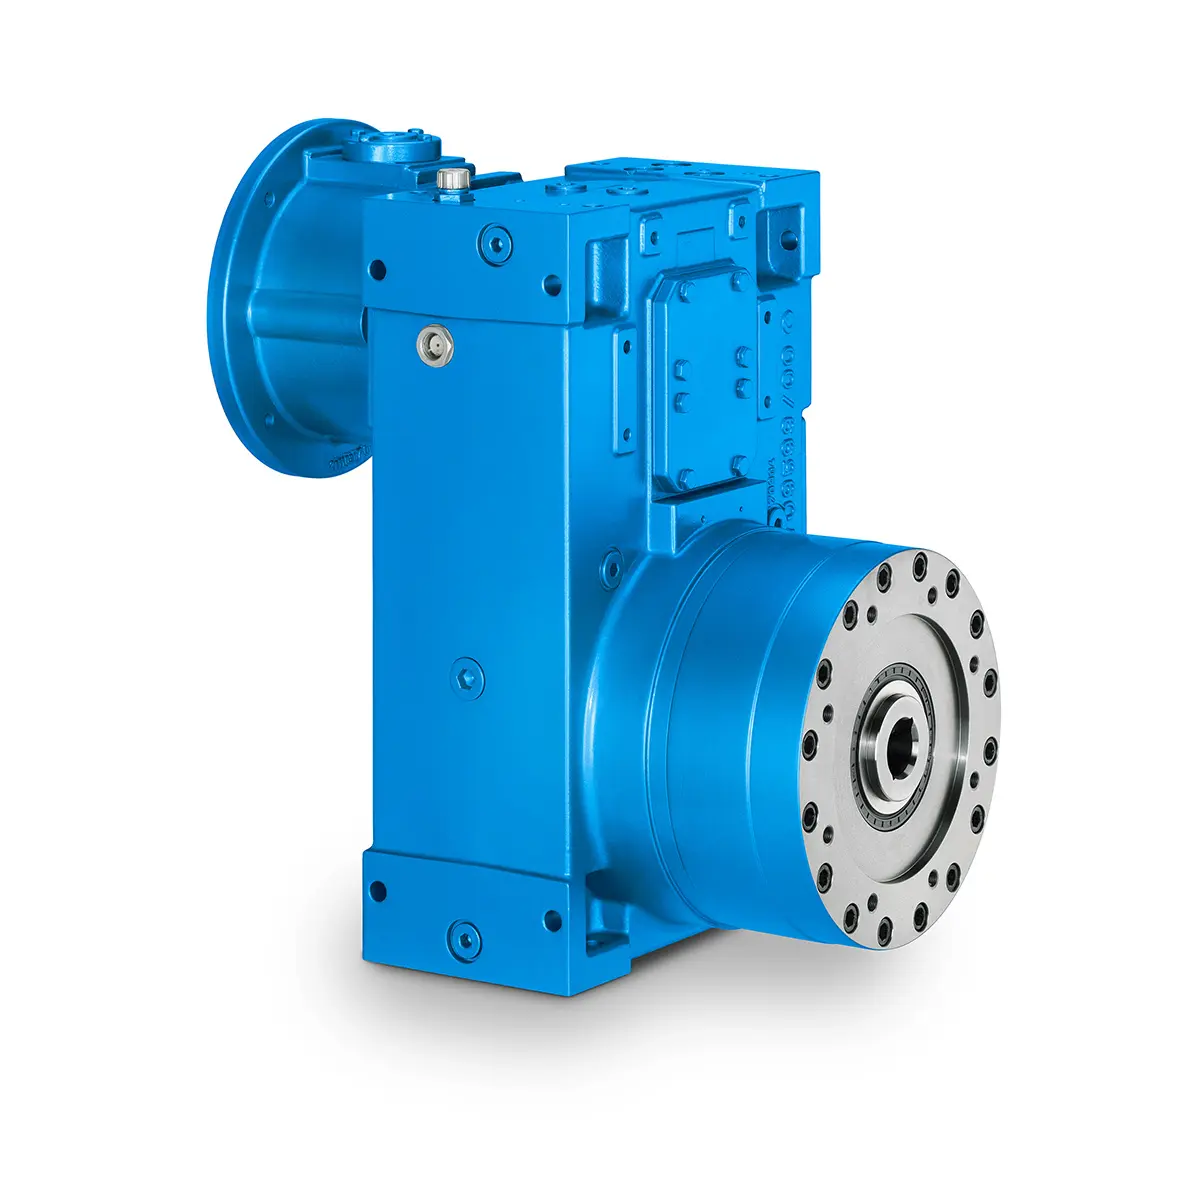 SINGLE SCREW Special industry dedicated gearunit gearbox
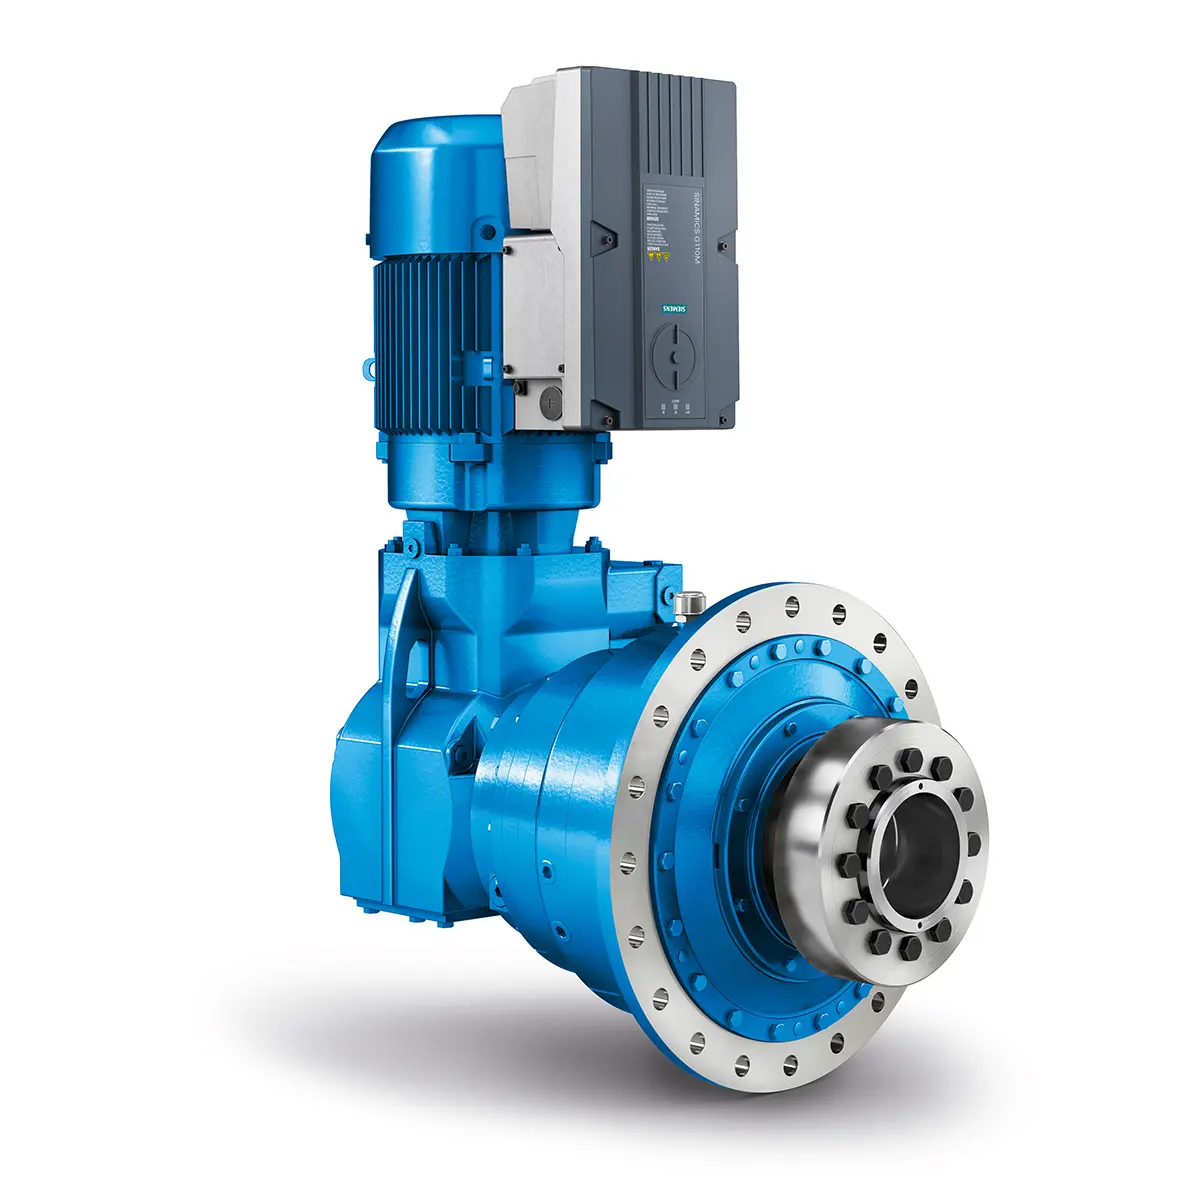 Playmaker In The Premium League
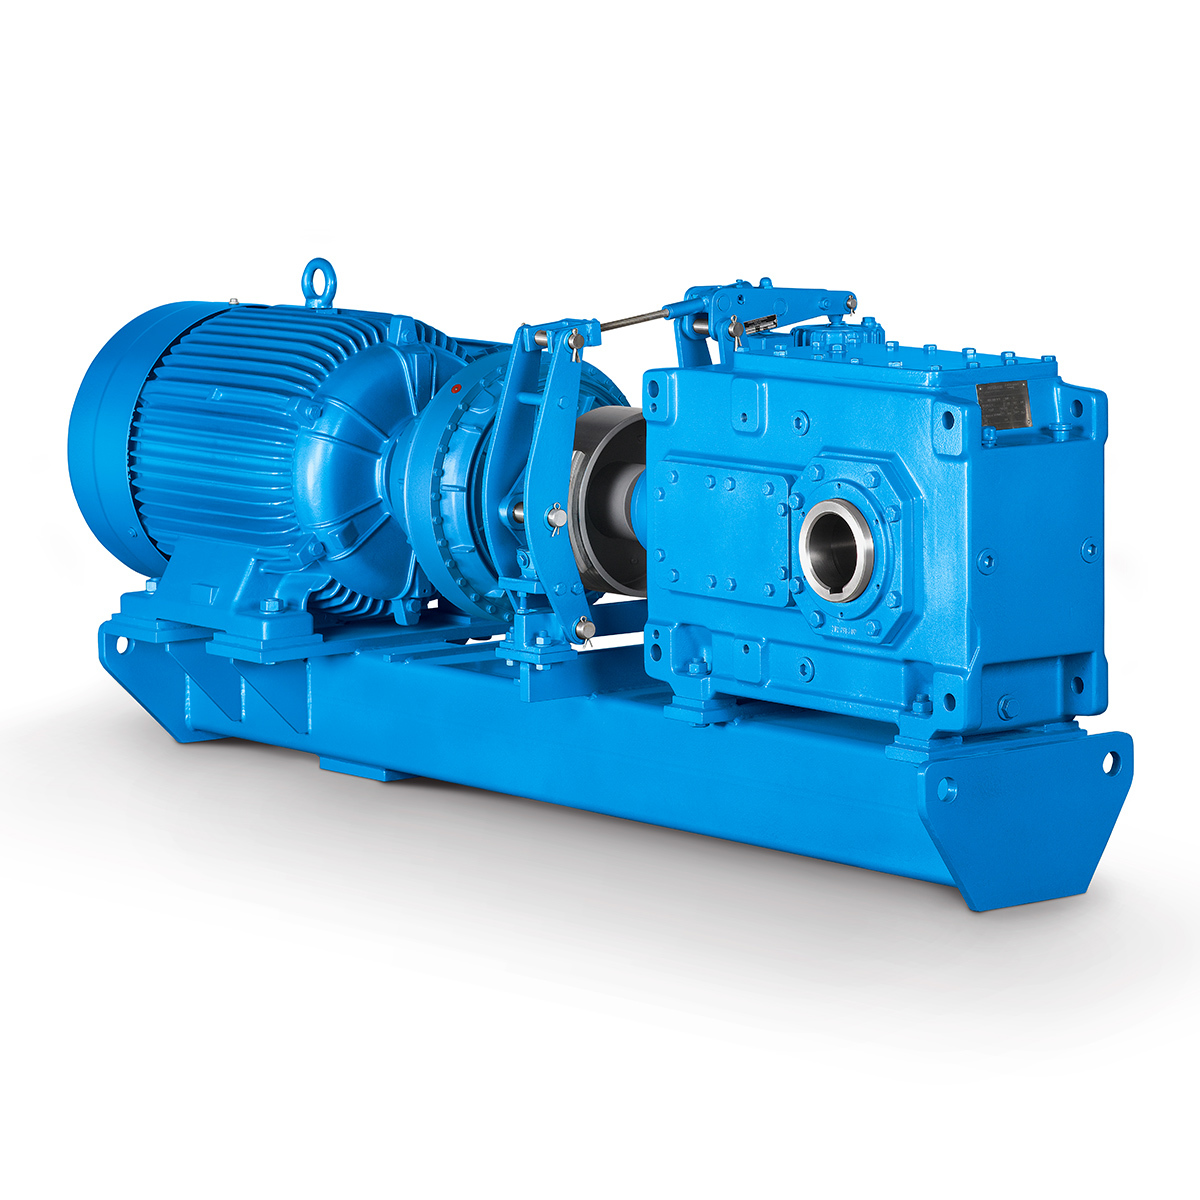 Conveyor belts gearunit gearbox
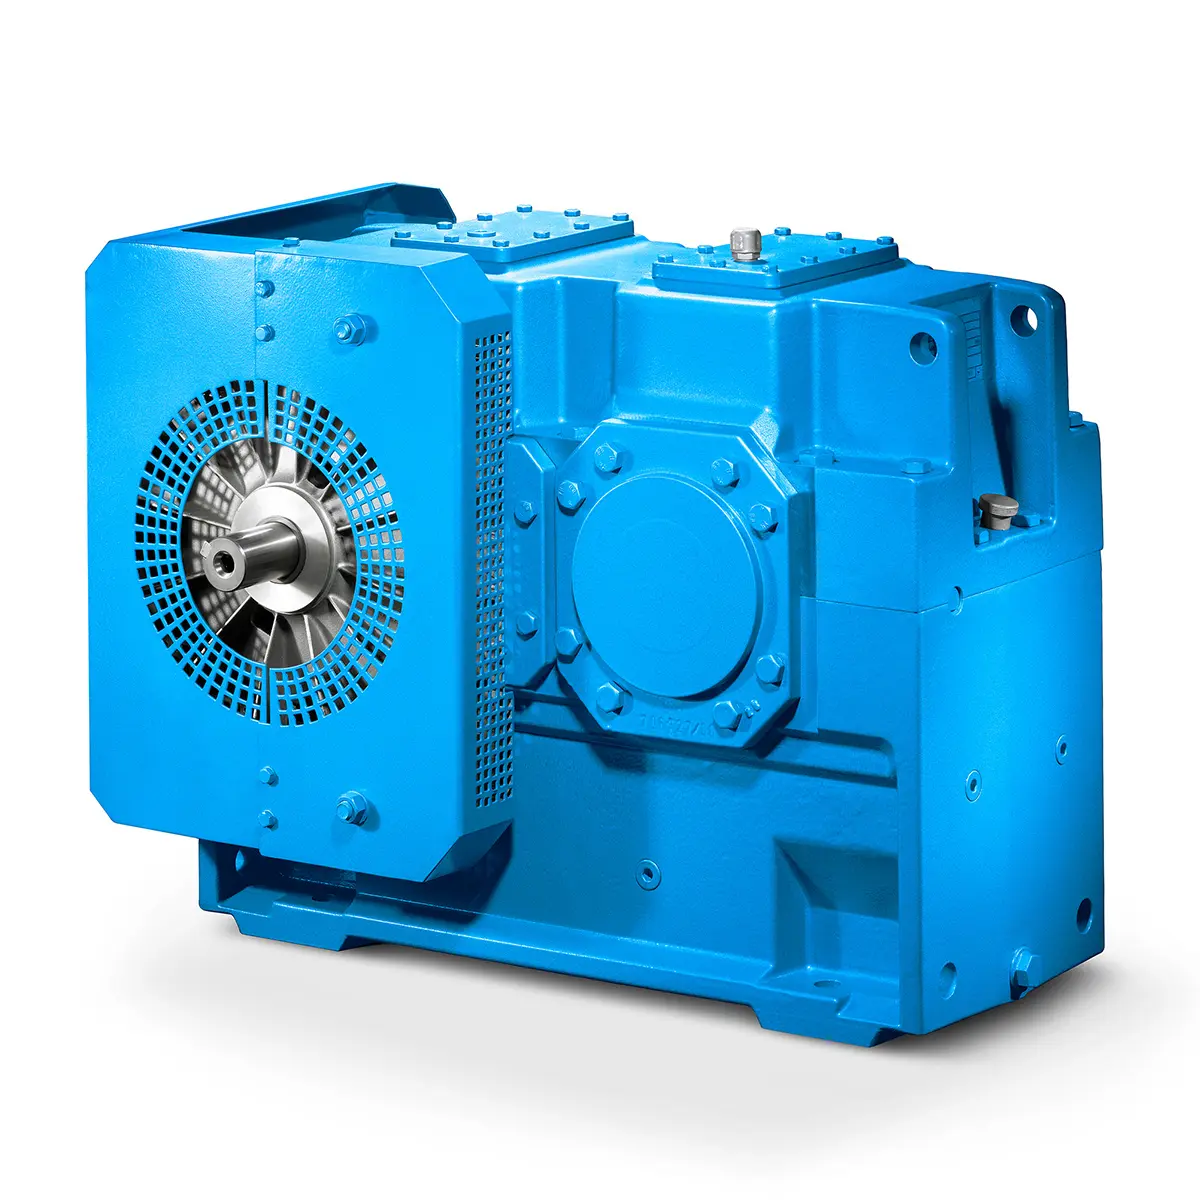 Paper And Pulp Preparation Sections
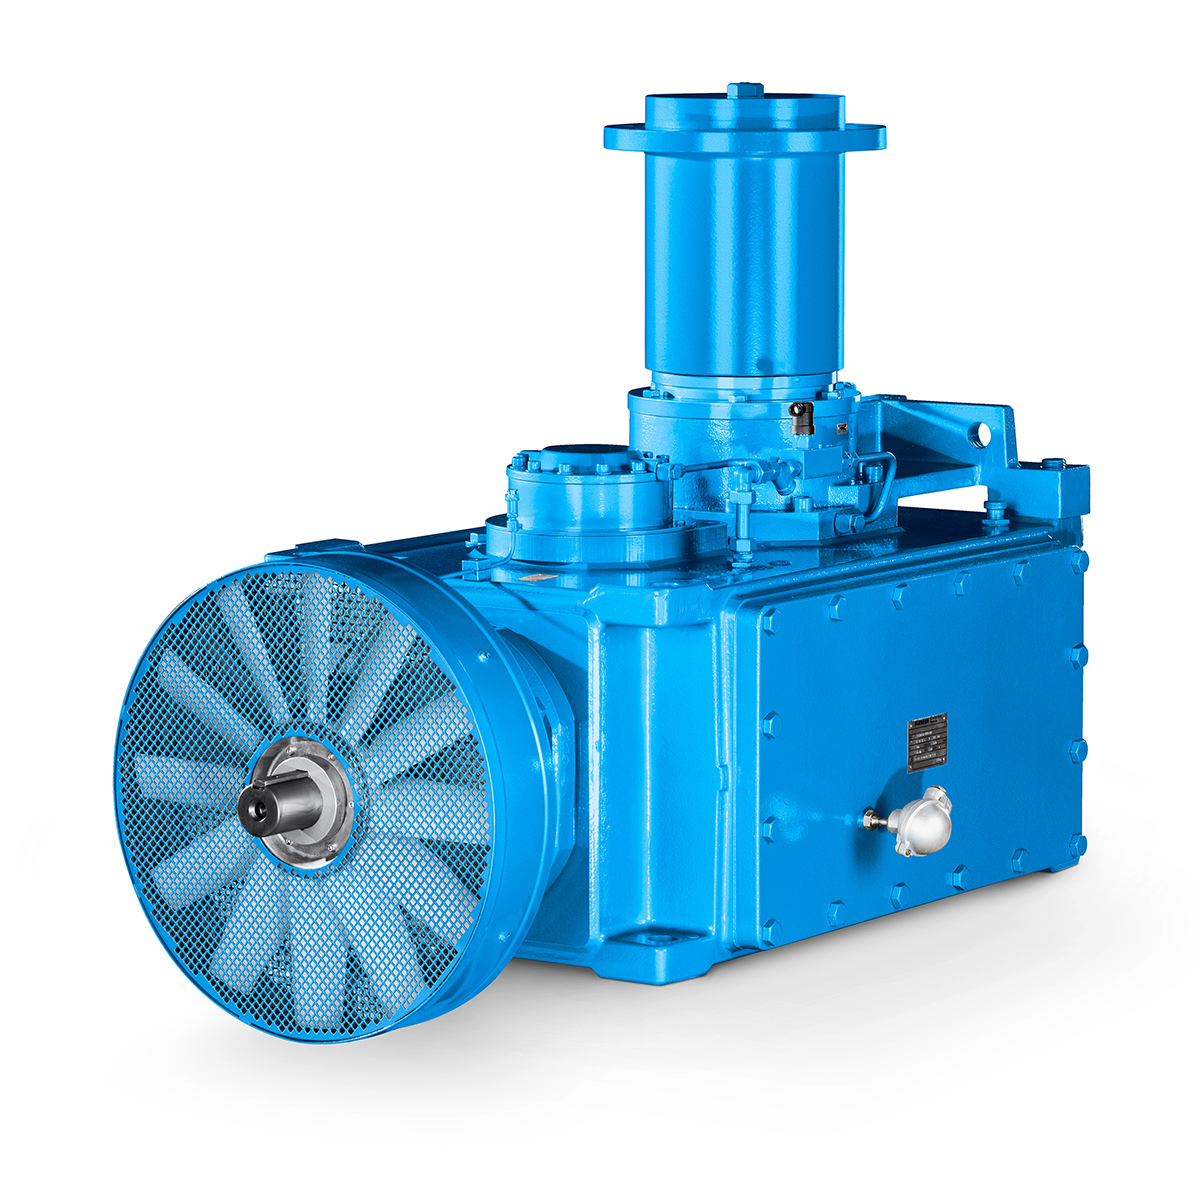 Operational Reliability Even In Case Of The Highest Ventilation Forces
 Reliable Gear Units For High Performance Vertical Conveyors 59/200
 Maximum power density – PLANUREX 3 L individual drives for your sugar cane mill
 The proven all rounder gearunit gearbox
 Stirs and stirs and stirs gearunit gearbox
 Flexibility on Board gearunit gearbox
 The right gearbox for all Multi-Engine Ships
 Reliable Power Generation on board
 Maximum performance level, fast deliverable
 Efficient and compact – FLENDER Gear Units for Sugar Mills
 Extremely strong. Extremely compact. Extremely stressable.
 FLENDER Coupling
 ZAPEX ZW Torsionally Rigid Gear Coupling
 ZAPEX ZN Torsionally Rigid Gear Coupling
 N-EUPEX Flexible high performance Coupling
 N-ARPEX Torsionally Rigid All-Steel Coupling
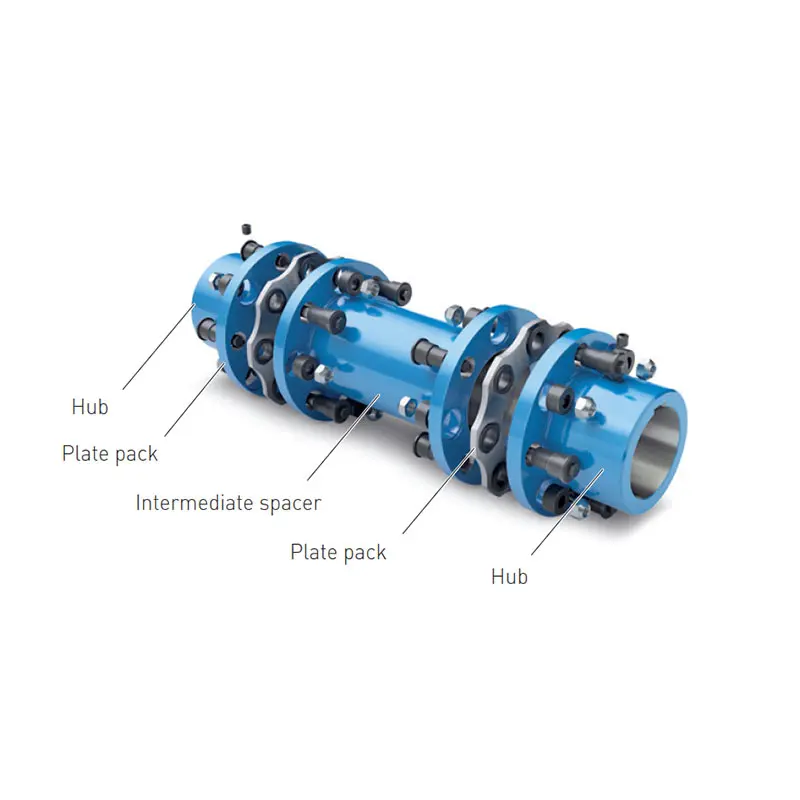 ARPEX Torsionally Rigid All-Steel Coupling Spare and Parts
 RUPEX Flexible high performance Coupling
 N BIPEX Flexible high performance coupling
 ELPEX B Highly Flexible Coupling
 ELPEX S Highly Flexible Coupling high performance
 ELPEX Highly Flexible Coupling high performance
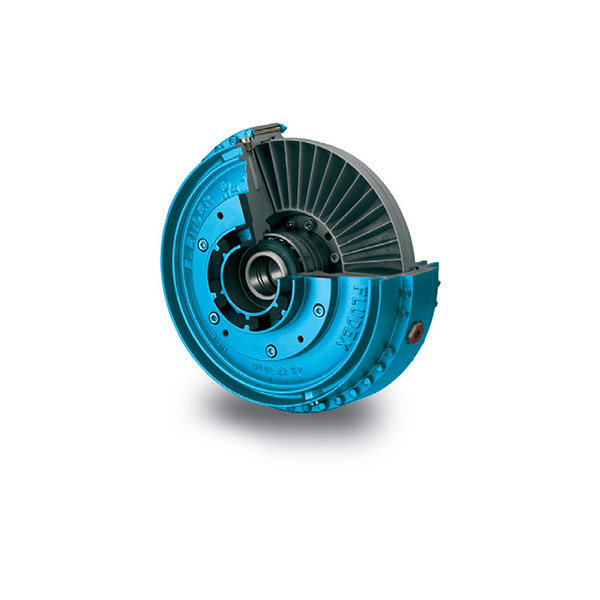 FLUDEX Fluid Coupling high performance
 SIPEX Backlash free Coupling high performance
 BIPEX S Backlash free Coupling high performance
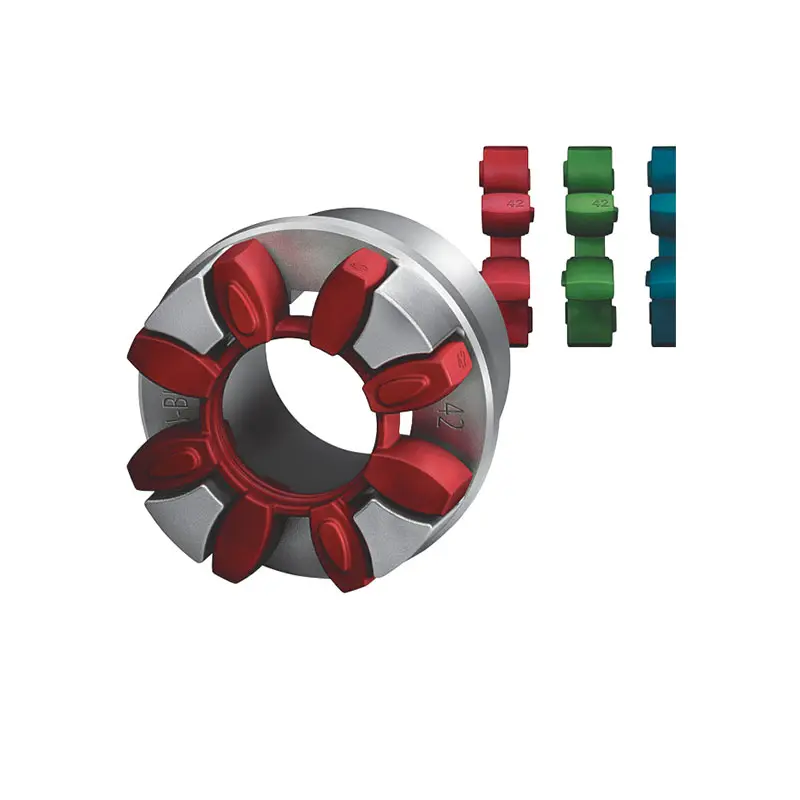 FLENDER Coupling Spare Parts high performance
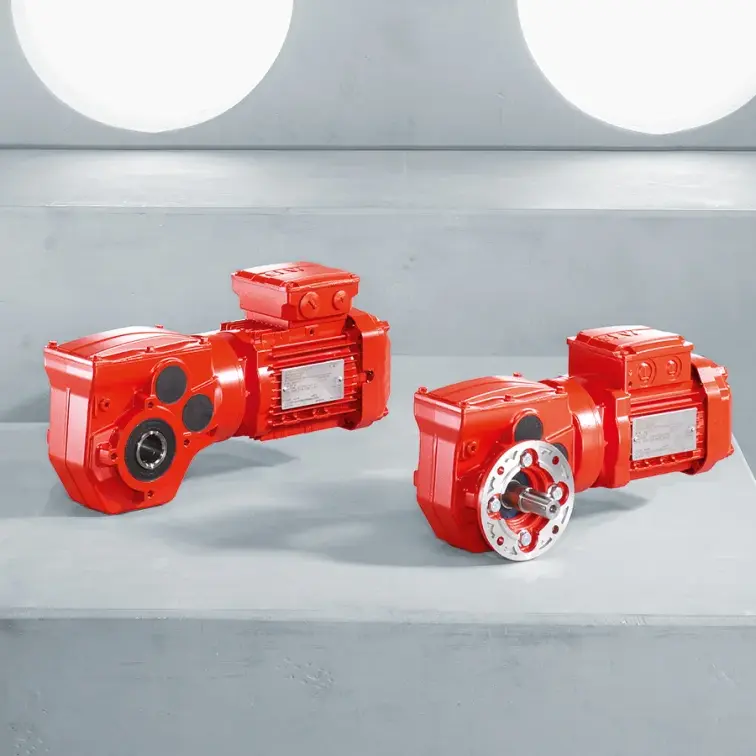 SEW Gearmotor
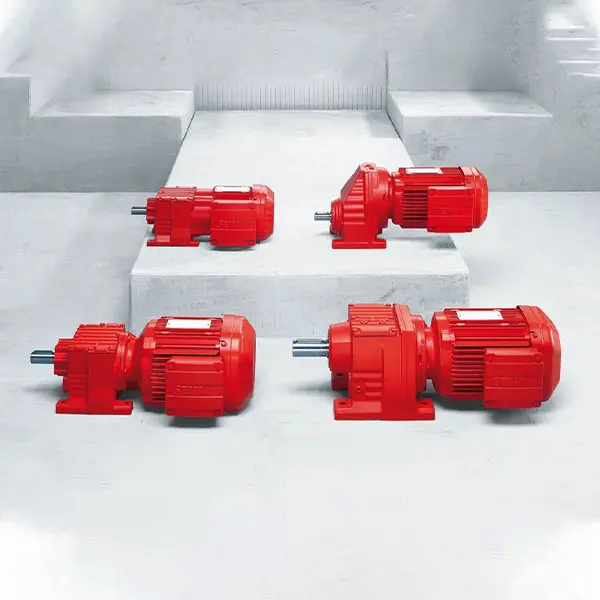 R Series Helical Gearmotor low voltage
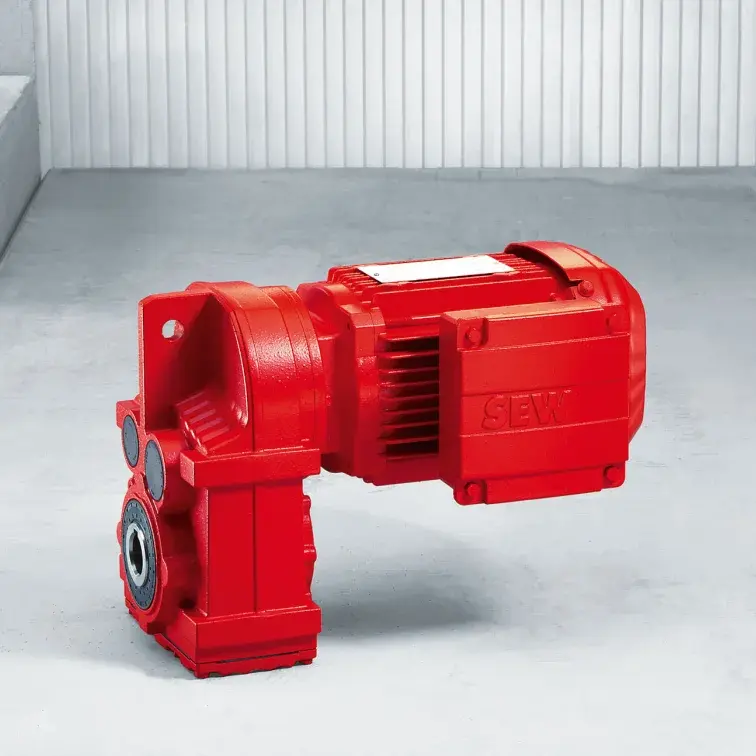 F Series Parallel Shaft Gearmotor low voltage
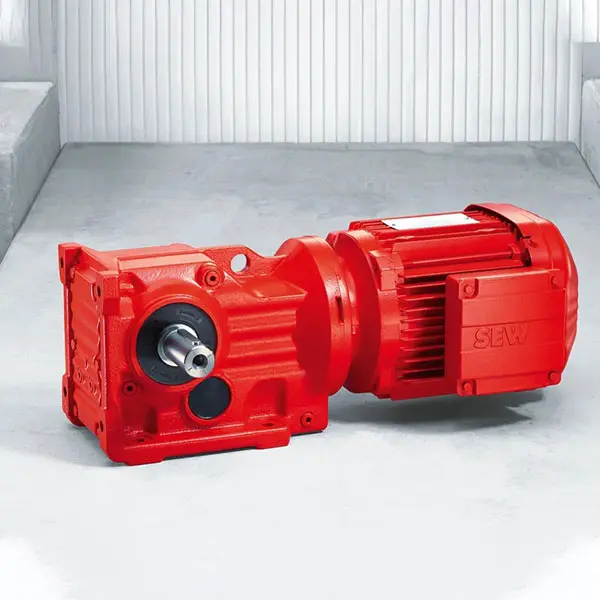 K Series Helical Bevel Gearmotor low voltage
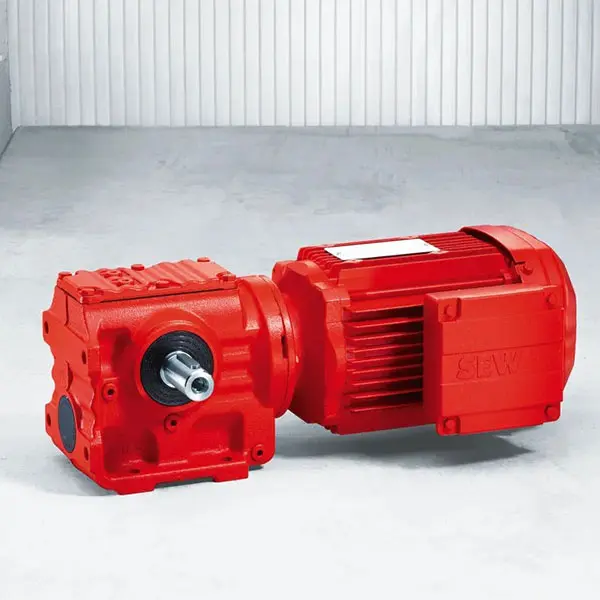 S Series Helical Worm Gearmotor low voltage
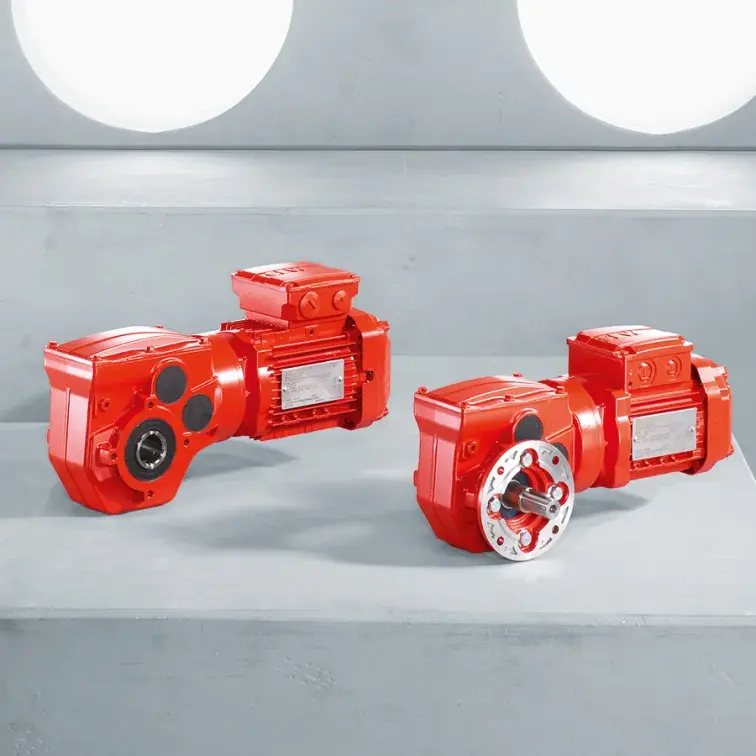 W Series SPIROPLAN® Right Angle Gearmotor